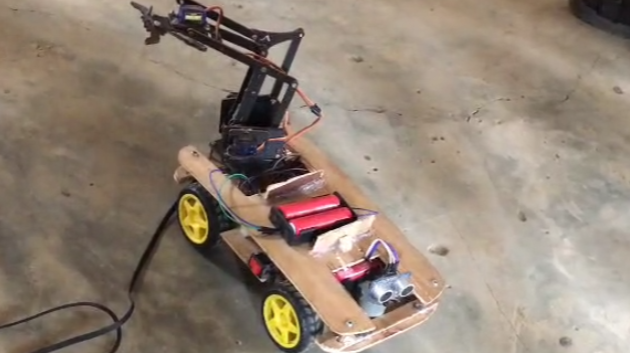
Hybrid Robot MCE321 Project
Project Overview
This project presents a hybrid robotic platform developed for the MCE321 Mechatronics Design and Robotics course, integrating manual remote control and autonomous navigation capabilities on a single ESP32-based system. The robot features a differential drive for agile mobility, a 3‑DOF robotic arm with a gripper for manipulation, and an MPU6050 inertial measurement unit for real‑time orientation tracking. PID controllers leverage IMU feedback to maintain straight‑line motion and achieve precise rotational turns. A PS3 controller provides intuitive manual command of both drive and arm functions, while an ultrasonic proximity sensor enables autonomous obstacle detection. In autonomous mode, the robot scans its surroundings using a stepper‑mounted sensor, identifies the clearest path, and navigates around obstacles without human intervention. The design demonstrates core mechatronics concepts including motor control, inverse kinematics, sensor fusion, and reactive behavior.
Skills Used
C++ Programming
Embedded Systems Design
Robotics
Control Theory
Collaboration